(WACV24) Our Research Work Reaches Hawaii!
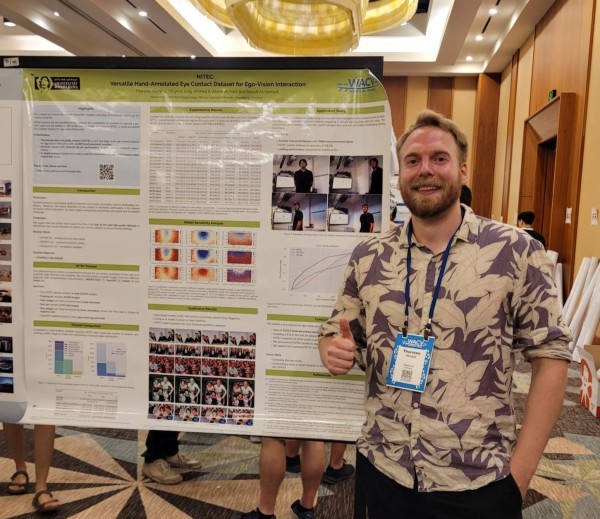
Our recent research on eye contact detection for human-robot interaction was accepted by WACV24 and presented at the conference in January 2024 in Hawaii, USA.
New publication presented at WACV24!
We are delighted to share our recent work on eye contact detection for human-robot interaction within the AutoKoWaT project. Our paper, ‘NITEC: Versatile Hand-Annotated Eye Contact Dataset for Ego-Vision Interaction,’ has been accepted by WACV, and we were invited to present our findings. This opportunity to engage with a diverse audience was a highlight, sparking engaging discussions.
Abstract
Eye contact is a crucial non-verbal interaction modality and plays an important role in our everyday social life. While humans are very sensitive to eye contact, the capabilities of machines to capture a person’s gaze are still mediocre. We tackle this challenge and present NITEC, a hand-annotated eye contact dataset for ego-vision interaction. NITEC exceeds existing datasets for ego-vision eye contact in size and variety of demographics, social contexts, and lighting conditions, making it a valuable resource for advancing ego-vision-based eye contact research. Our extensive evaluations on NITEC demonstrate strong cross-dataset performance, emphasizing its effectiveness and adaptability in various scenarios, that allows seamless utilization to the fields of computer vision, human-computer interaction, and social robotics. We make our NITEC dataset publicly available to foster reproducibility and further exploration in the field of ego-vision interaction.

Fulltext Access
Citing:
@InProceedings{Hempel_2024_WACV,
    author    = {Hempel, Thorsten and Jung, Magnus and Abdelrahman, Ahmed A. and Al-Hamadi, Ayoub},
    title     = {NITEC: Versatile Hand-Annotated Eye Contact Dataset for Ego-Vision Interaction},
    booktitle = {Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV)},
    month     = {January},
    year      = {2024},
    pages     = {4437-4446}
}